Yifei Yang.
Embodied AI · Robot Learning

Yifei Yang 杨逸飞

Undergraduate researcher · Expected graduation: June 2027

I am an undergraduate in Communication Engineering at Beijing Jiaotong University and Lancaster University. My research focuses on world models, visual navigation, and robot learning.

I am currently a research intern in Prof. Yan Wang's group at the Institute for AI Industry Research (AIR), Tsinghua University. I have also conducted research at The Chinese University of Hong Kong. I am interested in how robots can predict future states and use those predictions to plan and act in the physical world.

World ModelsVisual NavigationVision-Language-ActionIn-Context Learning

News

Research & milestones

Publications

Selected research · 2026
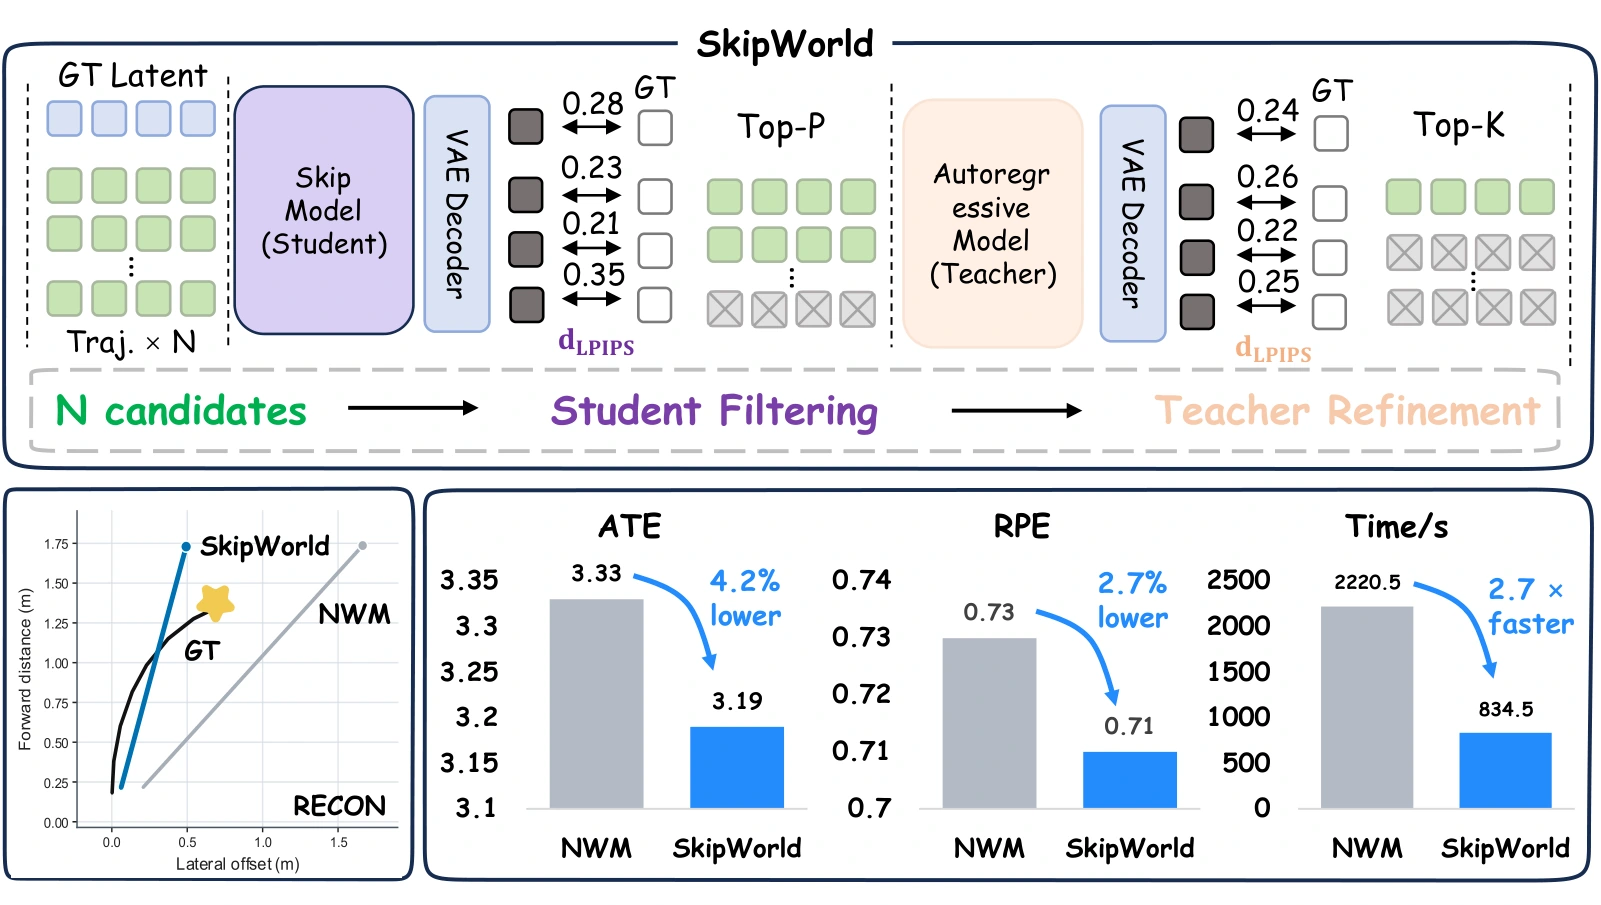
SkipWorld: candidate filtering, teacher refinement, and navigation results
Figure 1 · View full size ↗

SkipWorld: Latent Skip Planning with Distilled World Models for Efficient Visual Navigation

Yifei Yang, Zehua Fan, Zike Yan, Zhongyu Li, Yan Wang‡

‡ Corresponding author.

arXiv 2026 · Under review

Closed-loop latent prediction, long-stride distillation, and coarse-to-fine trajectory evaluation for efficient world-model-based navigation.

BibTeX

Google Scholar record ↗

@article{yang2026skipworld,
  title={SkipWorld: Latent Skip Planning with Distilled World Models for Efficient Visual Navigation},
  author={Yang, Yifei and Fan, Zehua and Yan, Zike and Li, Zhongyu and Wang, Yan},
  journal={arXiv preprint arXiv:2610.18135},
  year={2026}
}
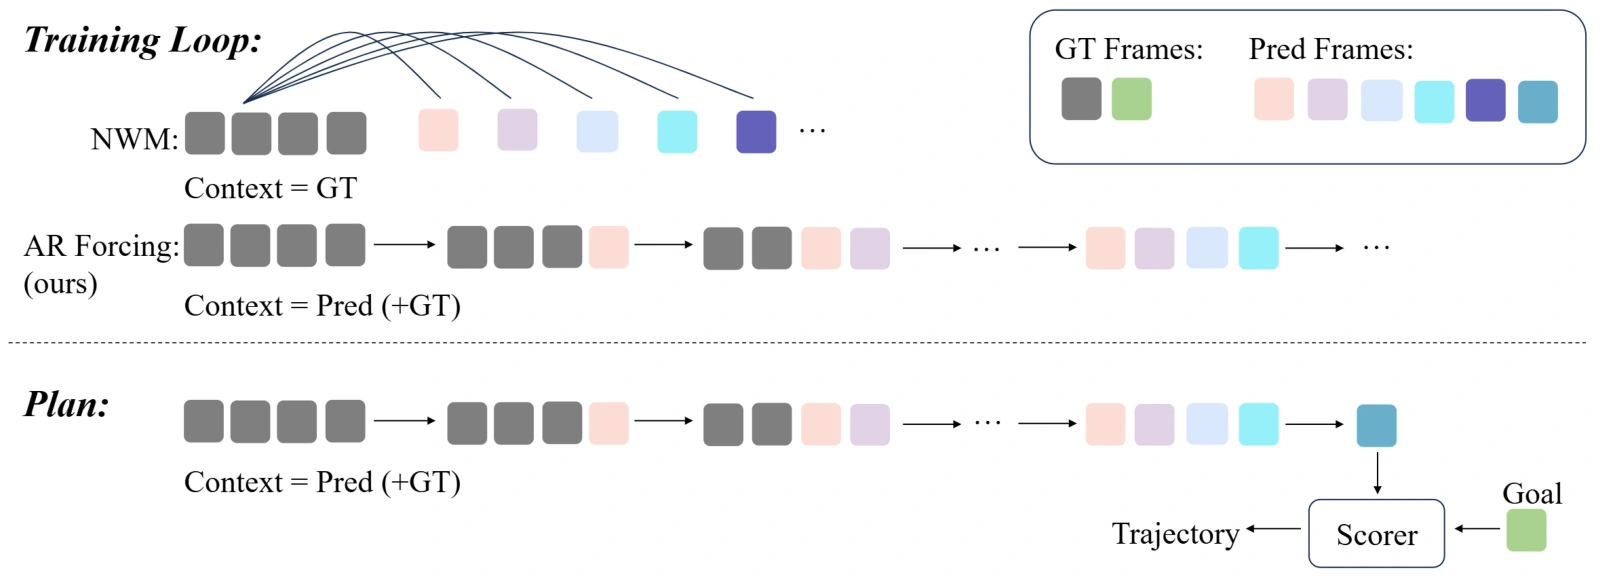
AR Forcing method: autoregressive training with predicted contexts and world-model planning
Figure 2 · View full size ↗

AR Forcing: Towards Long-Horizon Robot Navigation World Model

Yifei Yang, Zehua Fan, Huan Li, Aoqi Wang, Lida Huang, Haibao Yu, Haiyan Liu, Xuanyao Mao, Jason Bao, Liang Xu, Bingchuan Sun‡, Yan Wang‡

‡ Corresponding authors.

arXiv 2026

Autoregressive training with self-generated contexts to reduce the gap between training and closed-loop world-model inference.

BibTeX

Google Scholar record ↗

@article{yang2026ar,
  title={AR Forcing: Towards Long-Horizon Robot Navigation World Model},
  author={Yang, Yifei and Fan, Zehua and Li, Huan and Wang, Aoqi and Huang, Lida and Yu, Haibao and Liu, Haiyan and Mao, Xuanyao and Bao, Jason and Xu, Liang and others},
  journal={arXiv preprint arXiv:2605.31314},
  year={2026}
}
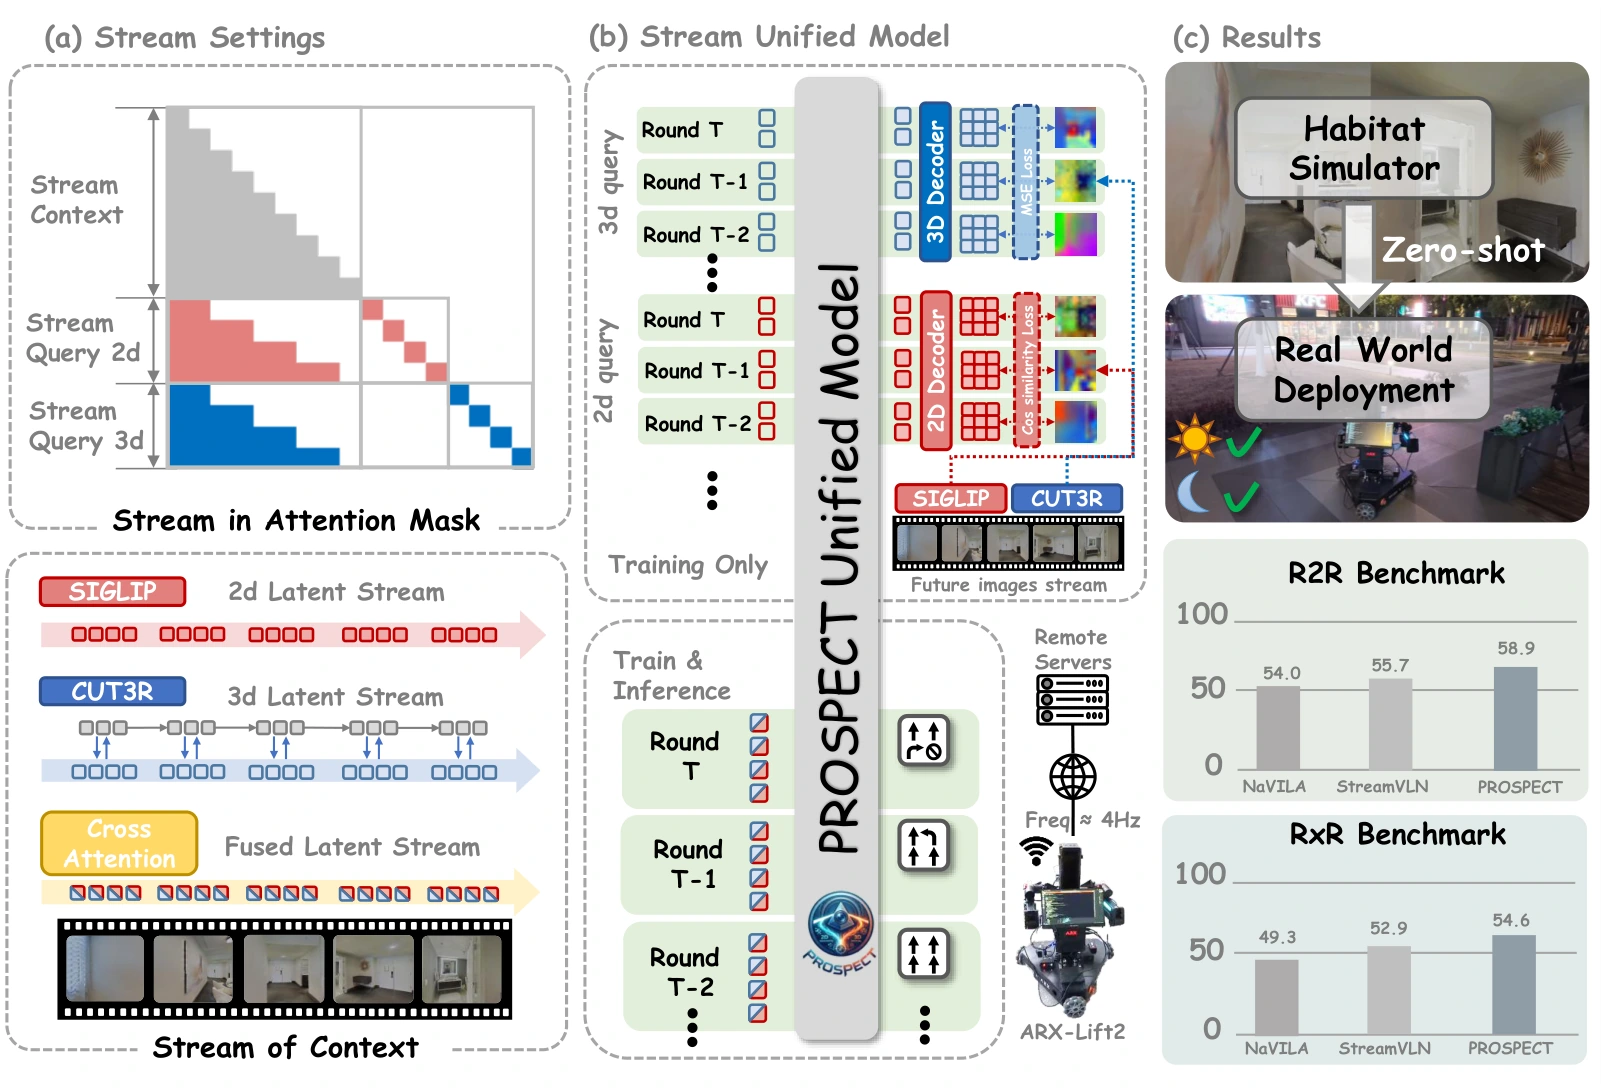
PROSPECT: streaming setup, unified model, and navigation results
Figure 1 · View full size ↗

PROSPECT: Unified Streaming Vision-Language Navigation via Semantic-Spatial Fusion and Latent Predictive Representation

Zehua Fan, Wenqi Lyu, Wenxuan Song, Linge Zhao, Yifei Yang, Xi Wang, Junjie He, Lida Huang, Haiyan Liu, Bingchuan Sun‡, Guangjun Bao, Xuanyao Mao, Liang Xu, Yan Wang‡, Feng Gao‡

‡ Corresponding authors.

Accepted by IEEE Robotics and Automation Letters (RA-L)

Fusing CUT3R spatial features and SigLIP semantics with latent predictive representations for streaming navigation.

BibTeX

Google Scholar record ↗

@article{fan2026prospect,
  title={PROSPECT: Unified Streaming Vision-Language Navigation via Semantic--Spatial Fusion and Latent Predictive Representation},
  author={Fan, Zehua and Lyu, Wenqi and Song, Wenxuan and Zhao, Linge and Yang, Yifei and Wang, Xi and He, Junjie and Huang, Lida and Liu, Haiyan and Sun, Bingchuan and others},
  journal={arXiv preprint arXiv:2603.03739},
  year={2026}
}
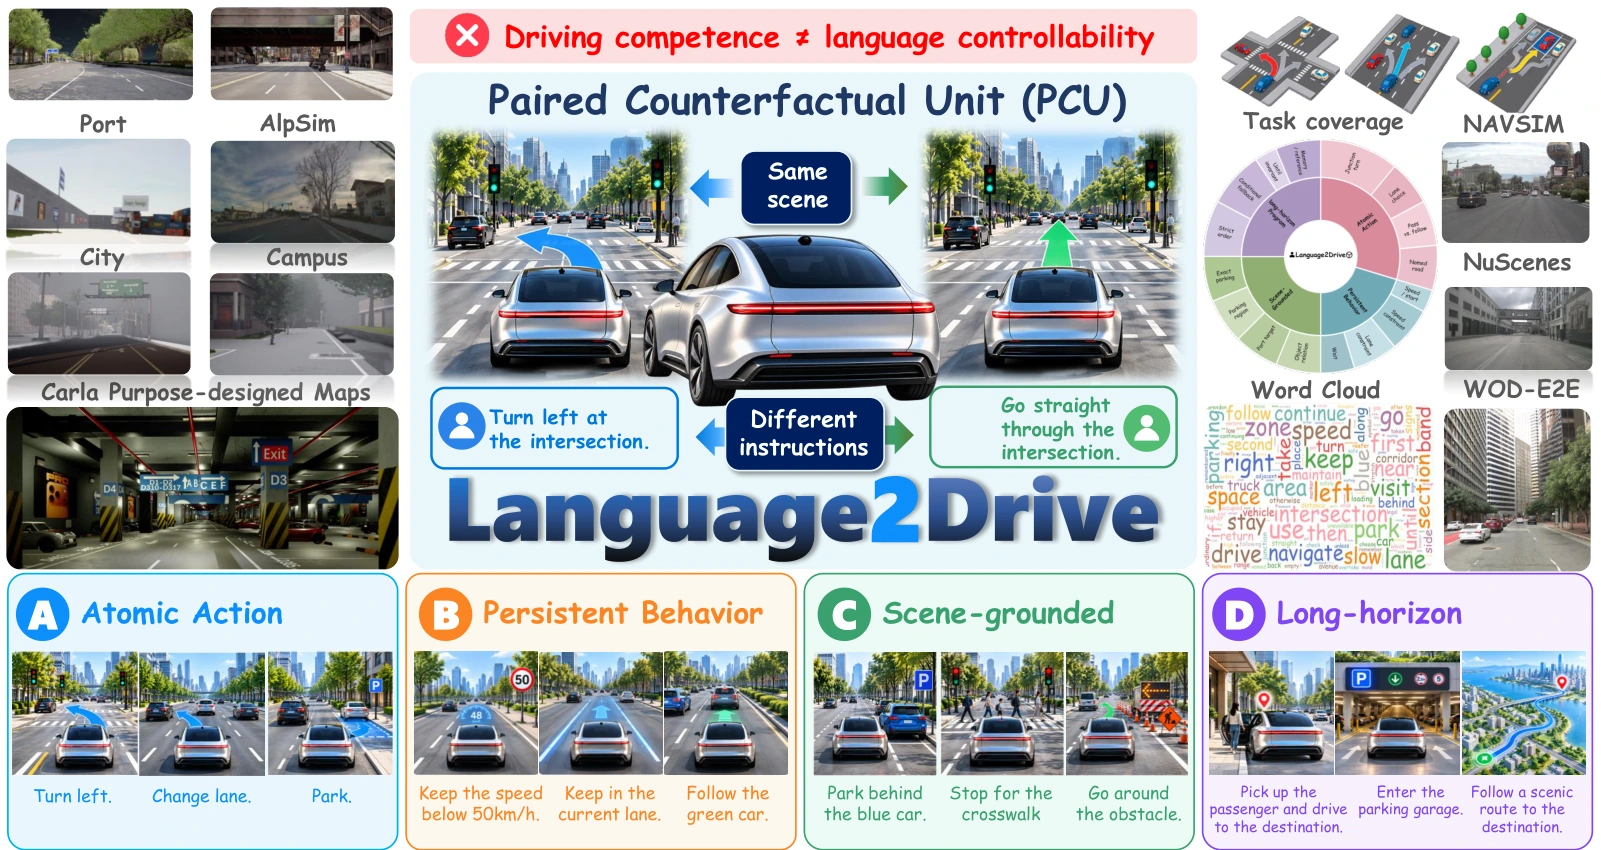
Language2Drive: paired counterfactual evaluation and four instruction-following scopes
Figure 1 · View full size ↗

Language2Drive: Do Vision-Language-Action Models Really Follow the Instructions in Autonomous Driving?

Zihan You*†, Zehua Fan*, Wenqi Lyu*, Aoqi Wang*, Ni Wang, Yifei Yang, Linge Zhao, Huan Li, Sining Ang, Yuguang Yang, Jueyu Chen, Xiangyu Li, Qianshan Wei, Jieyuan Pei, Yuxin Wang, Zhiwen Chen, Jiaqi Li, Wenxuan Song, Yanyuan Qiao, Benjin Zhu, Haoang Li, Yan Wang‡

* Core contributors · † Project Lead · ‡ Corresponding author.

arXiv 2026 · Under review

Studying language instruction following in vision-language-action models for autonomous driving.

BibTeX

Google Scholar record ↗

@article{you2026language2drive,
  title={Language2Drive: Do Vision-Language-Action Models Really Follow the Instructions in Autonomous Driving?},
  author={You, Zihan and Fan, Zehua and Lyu, Wenqi and Wang, Aoqi and Wang, Ni and Yang, Yifei and Zhao, Linge and Li, Huan and Ang, Sining and Yang, Yuguang and others},
  journal={arXiv preprint arXiv:2610.16634},
  year={2026}
}
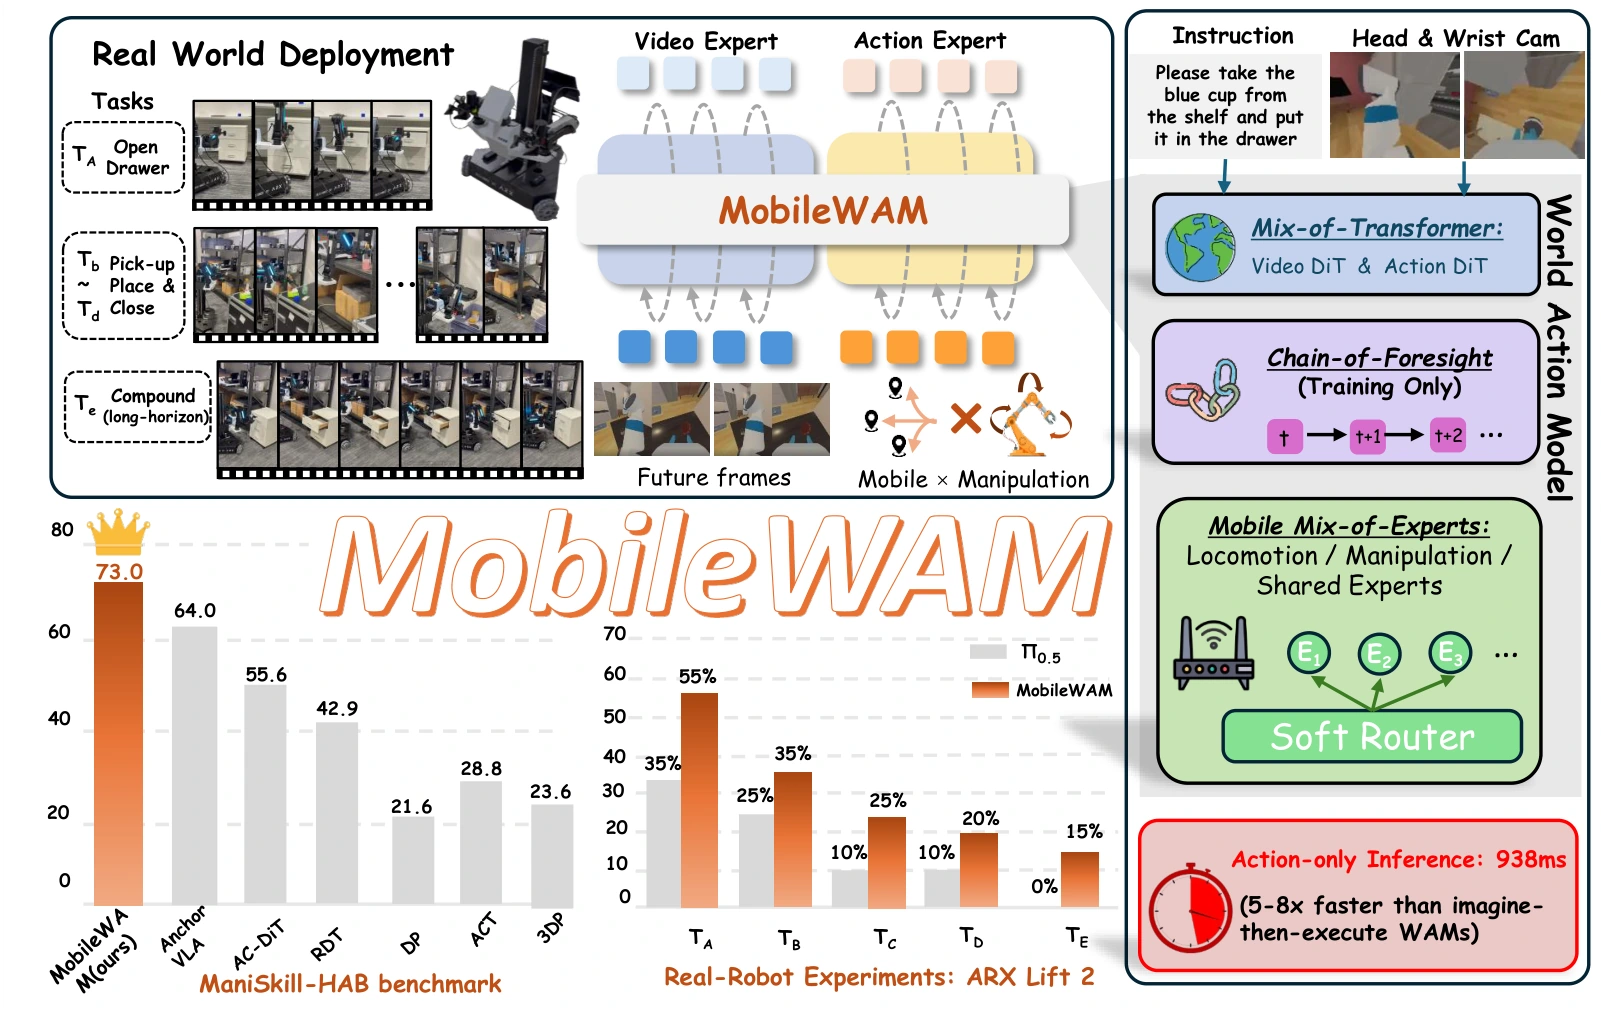
MobileWAM: real robot tasks, world action model, and manipulation results
Figure 1 · View full size ↗

MobileWAM: Bridging World Action Models to Mobile Manipulation with Chain-of-Foresight

Zehua Fan*, Junjie He*, Wenxuan Song*, Xi Wang, Wenqi Lyu, Linge Zhao, Fuhao Li, Zihan You, Yifei Yang, Kaiming Xu, Qi Jiang, Yue Jiang, Haoang Li, Cheng Chi‡, Feng Gao, Bailin Li‡, Yan Wang‡

* Equal contribution · ‡ Corresponding authors.

arXiv 2026 · Under review

Adapting video world models to mobile manipulation through sequential latent prediction and action learning.

BibTeX

Google Scholar record ↗

@article{fan2026mobilewam,
  title={MobileWAM: Bridging World Action Models to Mobile Manipulation with Chain-of-Foresight},
  author={Fan, Zehua and He, Junjie and Song, Wenxuan and Wang, Xi and Lyu, Wenqi and Zhao, Linge and Li, Fuhao and You, Zihan and Yang, Yifei and Xu, Kaiming and others},
  journal={arXiv preprint arXiv:2608.04657},
  year={2026}
}

Experience

May 2026 — Oct 2026

The Chinese University of Hong Kong

Research Intern · Advisor: Prof. Zhongyu Li

Latent skip planning and distilled world models for efficient visual robot navigation.

Dec 2024 — Present

Institute for AI Industry Research, Tsinghua University

Research Intern · Advisor: Prof. Yan Wang

Research on autoregressive navigation world models, streaming vision-language navigation, and mobile manipulation.

Jul 2025 — Aug 2025

Wuxi Research Institute of Applied Technologies, Tsinghua University

Algorithm Intern

Integrated robotic hardware and sensors in ROS2, implemented VLA model-to-control interfaces, and validated manipulation tasks on real robots.

May 2024 — May 2025

Beijing Jiaotong University

Undergraduate Innovation Project Leader · Advisor: Prof. Hang Zhou

Developed a low- and high-frequency feature fusion framework for anti-UAV detection and tracking. Received the Beijing Municipal Undergraduate Innovation Project Award.

Education

Beijing Jiaotong University

B.Eng. in Communication Engineering

Lancaster University

BEng Hons Electronics and Communications Engineering

Get in touch

For research discussions and collaboration in embodied AI.

yifei05.yang@gmail.com ↗